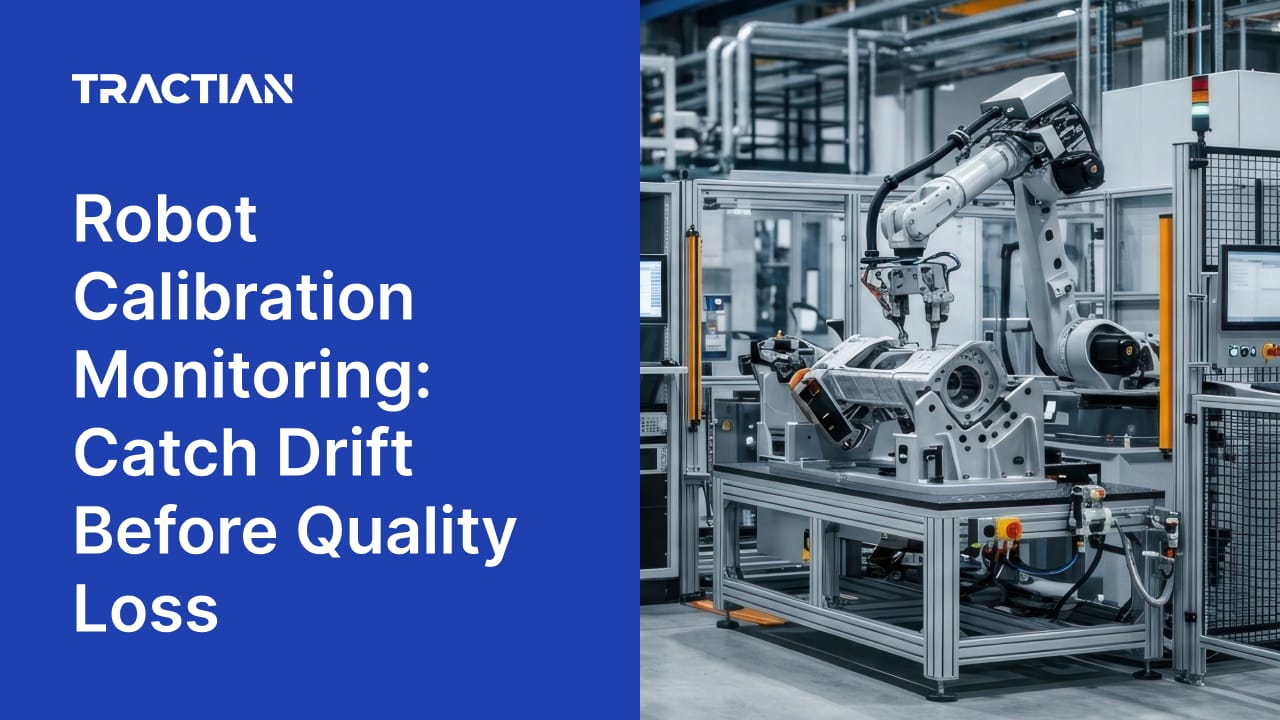
Your automated lines were sold to you as the predictable part of the plant. Robots don’t call in sick, don’t take vacation, and don’t vary their cycle time because it’s Friday afternoon. That predictability is exactly why so much committed output now sits behind them.
Which is also why the quiet failure mode of automation deserves more attention at the executive level than it usually gets. Robots rarely fail the way people expect. They do not stop one day out of nowhere. They drift. And because the controller is designed to hide that drift, the plant keeps running at what looks like full rate right up until the day it does not.
Robot calibration monitoring is the practice of watching that drift continuously instead of checking for it on a calendar. Here is why it matters to the people who sign the capital requests.
The three things worth knowing
1. The cost is already in your numbers, just not labeled. Unplanned downtime runs about $125,000 per hour for the typical industrial business, and closer to $2.3 million per hour in automotive, according to survey work from ABB and Siemens. Robot-driven scrap, unscheduled recalibration, and emergency joint replacements are already flowing through your maintenance, quality, and throughput variance lines today. They are simply distributed across enough accounts that nobody owns the total.
2. Calendar-based recalibration is a control that does not actually control the risk. Recalibrating every robot on a fixed interval means you pay for the work whether or not the asset needed it, and you still miss the units that degrade faster than the schedule assumes. You are buying activity, not assurance.
3. The payback case is built on four lines, not one. Avoided unplanned downtime is the headline, but the durable return comes from reduced scrap and rework, recovered calibration labor, and extended robot service life that pushes replacement capex further out. Build the business case on all four or you will understate it.
The failure you are actually paying for
Here is the part that makes automation different from the rest of the plant.
When a pump starts to fail, it gets loud, it gets hot, and someone notices. When a robot joint starts to fail, the robot compensates. Research presented to the PHM Society on harmonic drive failures in industrial robots lays out the mechanism plainly: as gear teeth wear and lubrication breaks down, backlash develops in the joint, and that backlash is automatically compensated through the encoder. The robot keeps arriving at the taught position. The part keeps getting welded. The quality check keeps passing.
Underneath that compensation, the drivetrain is consuming its remaining life. The same research maps the degradation to symptoms that are measurable well before the robot misses a position: inconsistencies between input and output shaft velocity, rising vibration signatures, increasing joint position error, and higher torque demand to hold the same motion profile.
In other words, the information exists. It has existed the whole time. Most plants just are not collecting it, because the robot has not given anyone a reason to look.
That is the structural problem. Every other major asset on the floor tells you it is sick. Robots are engineered to keep their symptoms to themselves.
What robot calibration monitoring actually does
Strip away the terminology and the approach is straightforward.
You instrument the servo motors and gearboxes with vibration and temperature sensors, and you pull current signature data from the servo drives. Then you establish what normal looks like for that specific robot running that specific program: the vibration profile of each joint through the motion cycle, the thermal behavior under load, and the current the motor draws to execute a known movement.
From there, the math does the watching. A joint that needs more current this month than it did last month to perform the identical motion is telling you that mechanical resistance has increased. A vibration signature that has shifted at a specific frequency is telling you which component moved. A gearbox running warmer on the same duty cycle is telling you lubrication has degraded.
None of that requires taking the robot out of production. None of it requires a technician with a laser tracker standing in a cell that has been locked out. It happens while the line runs, and it produces a trend line rather than a pass or fail verdict.
The practical output for an operator is a ranked list: which robots, across which cells, across which plants, are moving away from baseline and how fast. The practical output for you is a maintenance calendar built on evidence instead of assumption.
Where the money actually is
Most vendors will sell you the downtime number and stop there. It is the biggest single line, but it is not the whole case, and a business case built on one number is easy for a skeptical CFO to discount. There are four.
Avoided unplanned downtime. ABB's survey of 3,215 plant maintenance decision-makers found that more than two-thirds of industrial businesses experience unplanned outages at least once a month, and that 21 percent still rely on run-to-fail maintenance. On an automated line, a single robot failure does not cost you one station. It costs you the line, because the stations downstream have nothing to work on. That is the multiplier that makes automation downtime different from conveyor downtime.
Scrap and rework. This is the line most often left out, and it is frequently the one that moves fastest. Positional drift does not announce itself with a stoppage. It announces itself with weld placement creeping toward the edge of tolerance, dispensed bead position wandering, and fastener alignment getting marginal. By the time the quality system catches it, you have produced a population of suspect parts and you are deciding whether to sort, rework, or scrap the lot. Catching the drift at the joint means you never build the suspect population.
Recovered calibration labor. Count what you currently spend to recalibrate robots that did not need it. Every scheduled recalibration consumes planned downtime, skilled technician hours, and in many plants an outside service contract. Shifting even half of that population from calendar-driven to condition-driven is a direct operating expense reduction with no change to risk posture.
Extended asset life and deferred capex. A harmonic drive caught in early wear is a serviceable component. The same drive caught after it has damaged the joint is a replacement, and sometimes a robot replacement. Pushing robot retirement out by even two years across a large installed base changes the shape of your capital plan in a way that is worth modeling explicitly.
Stack those four and the return stops being a maintenance department argument. It becomes a margin argument.
Why this is getting more urgent, not less
The installed base is growing, and it is concentrating in exactly the sectors where line stoppages are most expensive.
The International Federation of Robotics reported that US industrial robot installations reached 38,000 units in 2025, an 11 percent increase over the prior year and the third strongest year on record. Automotive accounted for more than a third of those units. US robot density now stands at 307 robots per 10,000 manufacturing employees, against a global average of 132.
Two consequences follow from that, and both land on your desk.
The first is concentration of risk. Every point of automation density added is a point of output that no longer has a manual fallback. Reshoring and persistent skilled labor shortages are pushing more plants toward that profile, not fewer.
The second is a maintenance workforce problem. The technicians who can diagnose a degrading robot joint by feel are the same technicians who are retiring, and they are not being replaced one for one. Continuous robot calibration monitoring is one of the few interventions that captures that judgment in a system rather than in a person, which is why it tends to show up in workforce continuity planning as well as reliability planning.
The questions worth asking before you fund it
If your reliability team brings you a robot calibration monitoring proposal, these are the questions that separate a real program from a pilot that quietly dies in year two.
Does it cover the fleet or the favorites? A monitoring program on your three most troublesome robots tells you about three robots. The financial case depends on population coverage, because the value is in finding the failures you were not already watching for.
Does it survive a plant manager changing jobs? Programs that depend on one enthusiastic champion do not make it to the second budget cycle. Ask how alerts route, who is accountable for closing them, and what happens when that person is on vacation.
Can you compare Plant A to Plant B? If each site instruments differently, you get site-level insight and no portfolio view. Standardized deployment is what lets you see that one facility's robots are degrading twice as fast as another's, which is usually a process or environment finding worth more than the maintenance savings.
What is the measurement plan? Agree in advance on what you are tracking: unplanned robot-caused line stoppages, scrap attributable to positional defects, recalibration hours, and component replacement spend. Baseline them before deployment. A program without a baseline cannot prove anything at renewal, and you will be asked.
How fast does it install? Retrofit sensor deployment that does not require production interruption is the difference between a decision you can make this quarter and a project that has to wait for the next shutdown.
The honest framing
Automation did not remove risk from your operation. It concentrated it. Fewer assets now carry more of your committed output, and those assets are specifically engineered to conceal their own degradation until the compensation runs out.
Robot calibration monitoring is not a new philosophy of maintenance. It is a decision to stop accepting a blind spot that used to be unavoidable and is not anymore. The sensors are inexpensive, the installation does not stop the line, and the data starts producing a baseline within weeks.
The question in front of you is not whether your robots are drifting. Some of them are, right now, in a cell you would not have guessed. The question is whether you find out from a trend line or from a quality hold.
If you want to see what this looks like against your own fleet, let us walk through a plant and show you where the drift is. It is a shorter conversation than most people expect.